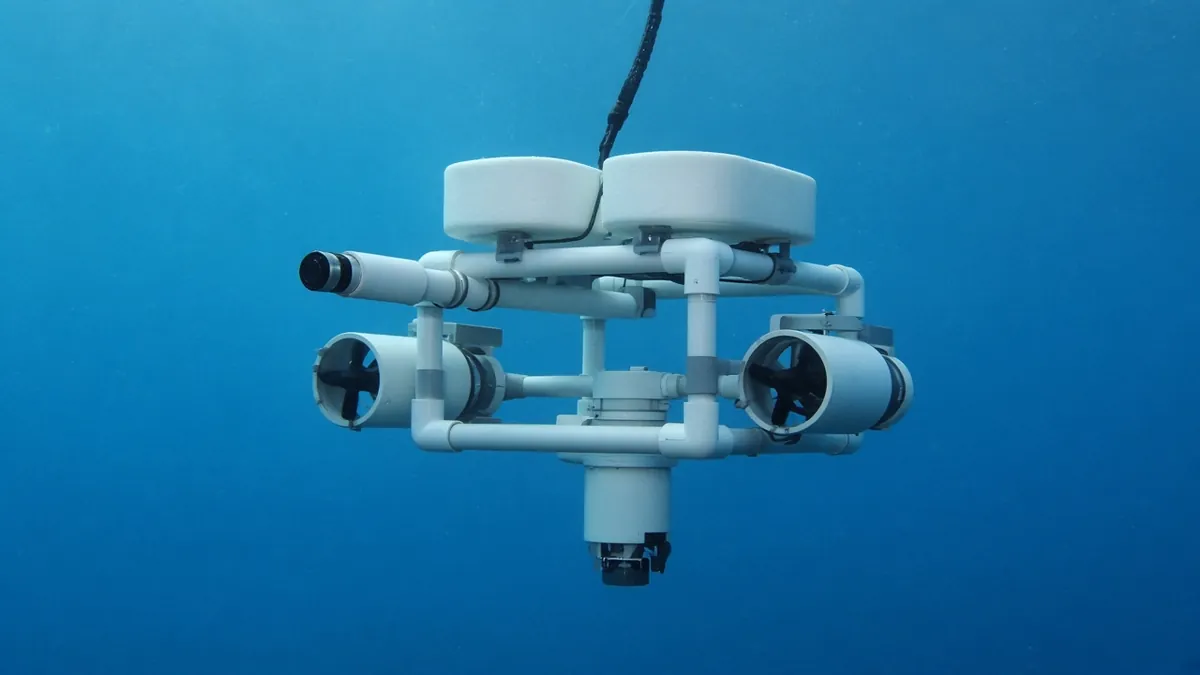
Tethered mini underwater ROV with a live camera
A PVC-frame underwater robot with three 12 V bilge-pump motors as thrusters (two to drive and turn, one to dive) and a waterproof USB endoscope camera. All electronics and the battery stay dry on the surface, connected by a 10 m tether.
Safety first
- Keep the battery, drivers and UNO dry on the surface. Only the sealed 12 V motors and the IP67 camera go under water. Never use mains power anywhere near the water.
- Fit the 10 A fuse right at the battery positive terminal. A shorted lead-acid battery can melt wires.
- Props can pinch fingers; disconnect power before handling the ROV.
- Never swim or wade after a snagged ROV in deep or cold water. Pull it in by the tether.
Rules and laws
- Get permission before using it in a pool, marina or private pond, and follow park rules. Do not disturb wildlife or film people in swimwear.
Parts
| Part | Qty | Approx. each | Subtotal |
|---|---|---|---|
| Rule 500 GPH 12 V bilge pumpUsed as a sealed 12 V motor: the strainer base and impeller come off and a printed propeller fits the shaft. Typical $22-35, no verified link.Amazon (search) | 3 | $28 | $84 |
| BTS7960 43A H-bridge motor driverOne per thruster, at the surface. Typical $6-12, no verified link.Amazon (search) | 3 | $8 | $24 |
| ELEGOO UNO R3 board with USB cableSurface controller. Catalog ASIN. Typical $14-22.Amazon | 1 | $17 | $17 |
| PS2-style analog joystick module (5-pack)Two joysticks: drive/turn and dive. Typical $6-10, no verified link.Amazon (search) | 1 | $8 | $8 |
| USB endoscope camera, 10 m cable, IP67Typical $20-45, no verified link.Amazon (search) | 1 | $30 | $30 |
| 16 AWG two-conductor speaker wire, 100 ftCut into three 10 m motor pairs. Typical $15-28, no verified link.Amazon (search) | 1 | $20 | $20 |
| 12 V 7 Ah sealed lead-acid batteryStays on the shore or boat. Typical $20-32, no verified link.Amazon (search) | 1 | $25 | $25 |
| 12 V SLA battery chargerSkip if you already own one. Typical $15-28, no verified link.Amazon (search) | 1 | $20 | $20 |
| Inline ATC blade fuse holder with 10 A fuseTypical $5-10, no verified link.Amazon (search) | 1 | $7 | $7 |
| 1/2-inch PVC tee and elbow fittings kitTypical $12-24, no verified link.Amazon (search) | 1 | $18 | $18 |
| 1/2-inch PVC pipe, 5 ftTypical $6-14, no verified link.Amazon (search) | 1 | $10 | $10 |
| Adhesive-lined heat-shrink tubing kitTypical $9-16, no verified link.Amazon (search) | 1 | $12 | $12 |
| Pool noodles (2-pack)Buoyancy foam, cut to trim. Typical $5-12, no verified link.Amazon (search) | 1 | $8 | $8 |
| Fishing sinker assortmentBallast for trim. Typical $7-14, no verified link.Amazon (search) | 1 | $10 | $10 |
| IP65 junction box, 150 x 110 x 70 mmSurface control box for the UNO and drivers. Typical $9-16, no verified link.Amazon (search) | 1 | $12 | $12 |
| Estimated total (parts only) | $305 | ||
Typical US prices, checked 2026-11-12. Prices change and multi-packs are often cheaper per piece.
As an Amazon Associate I earn from qualifying purchases. Prices change; check the store.
Filament
PETG (1.75 mm): about 120 g (39.6 m), roughly 7 h of printing.
PETG, 0.2 mm layers, 50% infill, 4 walls for the propellers and motor clamps.
AI agents you'll use
- Code helper (ChatGPT, Claude, Gemini or Grok): Writes the UNO sketch that turns two joysticks into three reversible motor commands with a deadband and soft ramps.
- Trim helper: Helps you work out how much foam and ballast to add so the ROV sits just barely positively buoyant and level.
Tools
- Soldering iron
- Heat gun for heat-shrink
- PVC pipe cutter or hacksaw
- Multimeter
- Laptop to view the camera
What you'll learn
- Thrust and buoyancy trim
- Reversible motor control with H-bridge drivers
- Waterproofing splices
- Designing for a tether
See what is at the bottom of the pool or the lake by the dock. This ROV keeps everything delicate on the surface, so the part that gets wet is just pipe, sealed motors and a waterproof camera.
What you'll build
A PVC frame about 35 x 25 x 15 cm with two horizontal thrusters at the back (forward, reverse and turning by speed difference) and one vertical thruster in the middle (dive and surface). A 10 m tether carries three motor pairs and the endoscope cable. At the surface a 12 V battery feeds three BTS7960 drivers controlled by an UNO with two joysticks, and the camera plugs into a laptop.
The cost range is $255-340. The low end assumes you already own these items marked "skip if you already own one": 12 V SLA battery charger. The high end includes them.
Print the parts
Print three propellers and three motor clamps. Measure the pump shaft diameter after removing the impeller and size the propeller hub to it. Search Printables for a "bilge pump ROV thruster" or ask the AI helper to help you model a simple 3-blade prop.
Wiring
| From | To | Notes |
|---|---|---|
| SLA battery + | 10 A fuse, then all three BTS7960 B+ terminals | |
| SLA battery - | All BTS7960 B- and UNO GND | Common ground. |
| BTS7960 #1 RPWM / LPWM | UNO D5 / D6 | Left thruster. |
| BTS7960 #2 RPWM / LPWM | UNO D9 / D10 | Right thruster. |
| BTS7960 #3 RPWM / LPWM | UNO D3 / D11 | Vertical thruster. |
| All BTS7960 R_EN and L_EN | UNO 5V | Enable both halves. |
| All BTS7960 VCC | UNO 5V | Logic supply. |
| Joystick 1 X / Y, Joystick 2 Y | UNO A0 / A1 / A2 | 5V and GND to both joysticks. |
| BTS7960 M+ / M- | Tether pair to each pump | Seal every splice with adhesive heat-shrink. |
| Endoscope USB | Laptop | Runs inside the tether bundle. |
Step-by-step
- Remove the strainer base and impeller from each pump and measure the shaft.
- Print and fit propellers; test each motor in a bucket.
- Build the PVC frame and clamp the thrusters on.
- Make the tether: three 10 m wire pairs plus the camera cable, taped every 50 cm.
- Solder and seal each motor splice with adhesive heat-shrink and test for leaks in a bucket.
- Wire the surface box and flash the joystick sketch.
- Trim in a pool: add foam and sinkers until it floats just barely and sits level.
- Drive in shallow, clear water first.
Code
Arduino UNO sketch with analogRead for the joysticks and analogWrite PWM to the BTS7960 inputs.
Prompt for the code helper:
Write an Arduino UNO sketch for a 3-thruster ROV: BTS7960 drivers on D5/D6 (left), D9/D10 (right), D3/D11 (vertical), with R_EN/L_EN tied high.
Joystick 1 on A0 (turn) and A1 (forward/back), joystick 2 on A2 (dive/surface). Mix forward and turn for the two horizontal thrusters, add a 10% deadband, limit PWM change to 10 steps per 20 ms, and stop all motors if a joystick reading is out of range.
Never drive RPWM and LPWM at the same time.
Troubleshooting
- ROV spins instead of going straight: The two horizontal props are not mirrored or one motor is reversed. Swap the leads or flip that prop.
- Will not dive: It is too buoyant. Remove a little foam or add a sinker.
- Motor stops after a dive: Water got into a splice. Re-seal with adhesive heat-shrink and dry the wire.
Files, code and docs
Last checked 2026-11-12. Double-check parts against your own board and seller listings before you buy.